
Ellipse Eccentricity⚠ unverified
Geometry / Analytic · Eccentricity of an ellipse a≥b
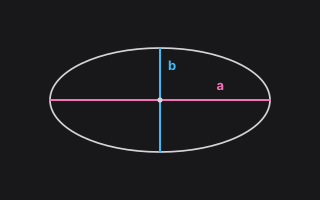
Parameters
| Input | Symbol | Unit | Default | Description |
|---|---|---|---|---|
| a | a | m | 5 | Semi-major axis |
| b | b | m | 4 | Semi-minor axis |
| Output | Symbol | Unit | Description |
|---|---|---|---|
| e | e | — | Eccentricity |
The science & history
Understanding the Parameters
- a (m) — Semi-major axis.
- b (m) — Semi-minor axis.
- Output e — Eccentricity.
How to Calculate
- Enter Semi-major axis as
a(default 5 m). Use the unit menu when you need a different unit. - Enter Semi-minor axis as
b(default 4 m). Use the unit menu when you need a different unit. - Click Calculate. The card evaluates $e=\sqrt{1-b^2/a^2}$ and shows the result in the declared output unit; Result in (when present) converts that number.
The Science: A Rigorous Derivation (Approaching a Proof)
Analytic geometry replaces figures with equations. A point is a tuple of real numbers; the Euclidean distance is the $2$-norm of their difference. A line $ax+by+c=0$ is a level set of a linear function, so the distance from a point to the line is that function's value divided by the norm of its gradient. Conics are the quadratic curves; completing the square on $x^2+y^2+Dx+Ey+F=0$ yields a circle; $e = c/a$ classifies ellipse ($e<1$), parabola ($e=1$) and hyperbola ($e>1$). Polar coordinates $(r,\theta)$ are the Euclidean plane written in rotationally natural coordinates.
Dimensional check. The declared output unit is dimensionless; ToolBox evaluates the
formula in SI (radians internally for every trigonometric call) and python-calc converts to
the unit on the card.
History and Development
- Descartes, La Géométrie (1637), and Fermat. Coordinates as a method; the name “Cartesian.”
-
Apollonius of Perga (3rd century BCE). Conics — ellipse, parabola, hyperbola — centuries before coordinates, in purely geometric language.
-
Euler, Lagrange. Rotation of axes to eliminate $xy$ terms; classification of the general conic.
-
19th century. Vector geometry (Gibbs, Heaviside) rewrites point-to-plane and skew-line distance as $|(\mathbf{P}_2-\mathbf{P}_1)\cdot(\mathbf{d}_1\times\mathbf{d}_2)|/|\mathbf{d}_1\times\mathbf{d}_2|$.
Related Concepts: Distance 3D, Slope, Angle Between Two Lines, Point To Line Distance, Circle Radius From General Form, Parabola Latus Rectum, Ellipse Linear Eccentricity, Hyperbola Eccentricity